Overview
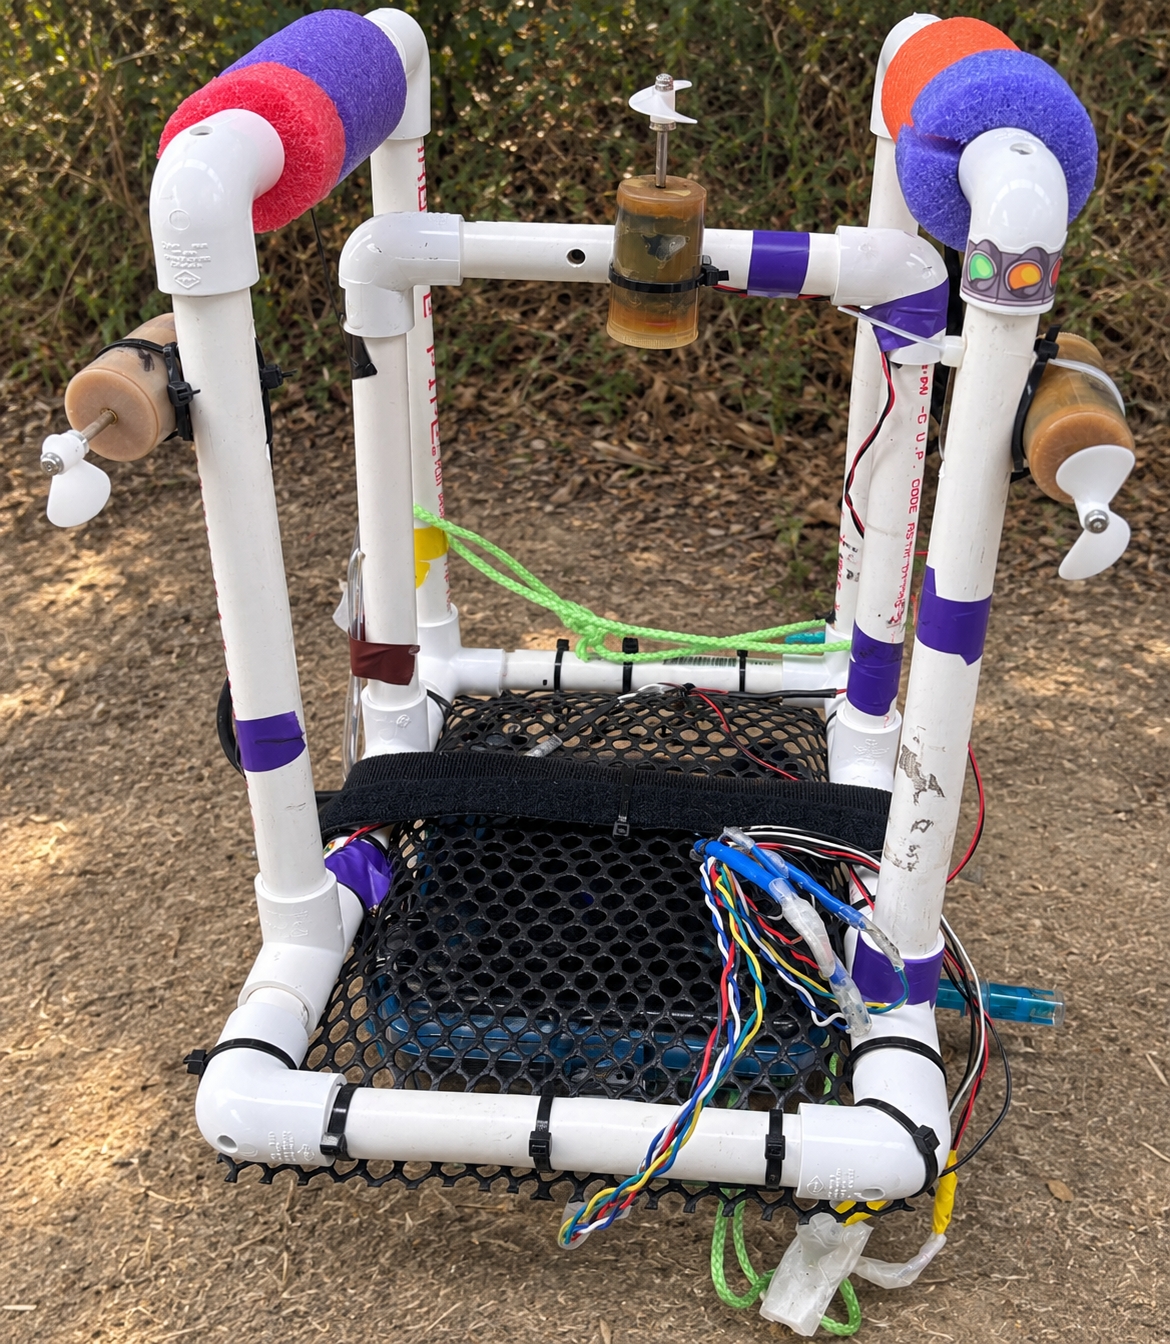
Water quality changes with depth. To study how pH and turbidity vary below the surface, the team built and tested an underwater robot that could carry sensors into the water column.
Waterproofing and circuit reliability were treated as first-class design constraints, not afterthoughts — the robot had to keep working once it was submerged.
What I did
- Developed and tested an underwater robot to explore relationships between depth, pH, and turbidity.
- Integrated reliability engineering principles into the design of waterproof circuits and protoboard layouts.
- Coordinated mechanical, digital, and electrical components to ensure robust robot movement.
Outcome
The robot provided a working platform for collecting depth-linked water-quality data, with waterproofing and circuit reliability designed in from the start.